Since their debut on 1960s industrial production lines, robots have continually expanded into higher-precision fields like medical technology and micro-assembly. A key driver behind this evolution has been advanced force sensing. By equipping controllers with real-time force feedback, modern load cells and multi-axis sensors enable robots to go beyond repetitive tasks, handling delicate assembly and adaptive gripping. Adding AI technology expands these capabilities further, including humanoid robotics.
Key Takeaways
- Commercial Sensor Placement: Robotic architectures utilize miniature load buttons in cable/tendon drives, torque transducers at motor joints, and multi-axis load cells at tool wrists.
- Sensor Taxonomy: “Load cell” typically refers to single-axis weight or tension measurement, while “force sensor” or “multi-axis transducer” encompasses multi-directional (\(F_x, F_y, F_z\)) and moment (\(M_x, M_y, M_z\)) feedback.
- Industry Robotics Trends: Rapid growth in cobots, humanoid robotics, and autonomous material handling relies on integrated multi-axis sensing at joint linkages and tool centers.
- Essential Control Loop Feedback: Force sensors and load cells provide real-time force feedback, enabling robots to execute delicate assembly, compliant gripping, and safe human-robot collaboration.
“Load Cells” vs. “Force Sensors” in Robots
While “load cell” and “force sensor” rely on the same core physics of converting mechanical deflection into a measurable electrical signal, the distinction comes down to application, directionality, and form factor.
In industrial weighing, a load cell typically measures static, gravity-aligned weight along a single predefined axis. In robotics, feedback loops require dynamic, multi-directional force vectors (\(F_x, F_y, F_z\)) and rotational moments (\(M_x, M_y, M_z\)) rather than simple weight. For this reason, engineers favor the term force sensor (or force transducer).
Furthermore, while traditional load cells use strain gauges bonded to steel or aluminum flexures, robotic force sensing spans diverse form factors from packaged multi-axis load cells at the robot wrist to miniature load buttons embedded in cable-driven joints and flexible tactile skins at the end-effector.
Robotics Trends & Technical Innovations: Cobots, Humanoids, and Force Feedback
The industrial robotics landscape has evolved far beyond caged, single-axis factory arms. Modern manufacturing, logistics, and medical fields favor collaborative robots (cobots), autonomous mobile robots (AMRs), and humanoid manipulators designed to operate alongside humans in dynamic environments.
Rather than relying on rigid, pre-programmed motion paths, next-generation robotic architectures integrate real-time force feedback directly into high-speed control loops. This transformation is driven by key breakthroughs across AI control, transducer engineering, and telemetry:
- Force Feedback in Closed-Loop Control: Continuous force feedback lets a controller adjust arm movement when a tool meets resistance, without stopping for reprogramming. Learning-based control methods increasingly build on this feedback.
- MEMS & Micro-Scale Sensing: Micro-machined silicon and thin-film sensing elements make multi-axis force sensing possible in very small tools, such as surgical instruments and compact grippers, where conventional foil strain gauges may not fit.
- Durable Flexure Materials: Improved flexure alloys and bonding materials help sensors hold a stable zero over many load cycles in high-vibration cobot applications.
- Onboard Digital Output: Some transducers now digitize the signal inside the housing before sending it over a bus such as CANopen, EtherCAT, or SPI. Digitizing at the sensor reduces exposure to electrical noise from nearby joint motors. (For traditional analog load cells, pairing with compact signal conditioners remains vital for clean signal conversion.)
New Applications for Robotic Force and Tactile Sensors
These innovations have opened the door to an array of applications in robotics. By continuously monitoring multi-vector forces and rotational moments, collaborative and autonomous manipulators can execute delicate, high-precision tasks that vision systems alone cannot manage:
- Micro-Tolerance Assembly: Inserting tight-clearance pins, engine pistons, and PCB connectors where optical cameras lack axial depth perception.
- Adaptive Surface Finishing: Maintaining constant, uniform contact force during automated grinding, deburring, polishing, and sanding across irregular geometries.
- Compliant Material Handling: Regulating gripper force on delicate workpieces, such as thin-walled glass, silicon wafers, and agricultural produce, to prevent crushing or dropping.
- Precision Product Testing: Applying exact, repeatable push-pull loads to validate mechanical switches, structural flexures, and consumer hardware in automated QA rigs.
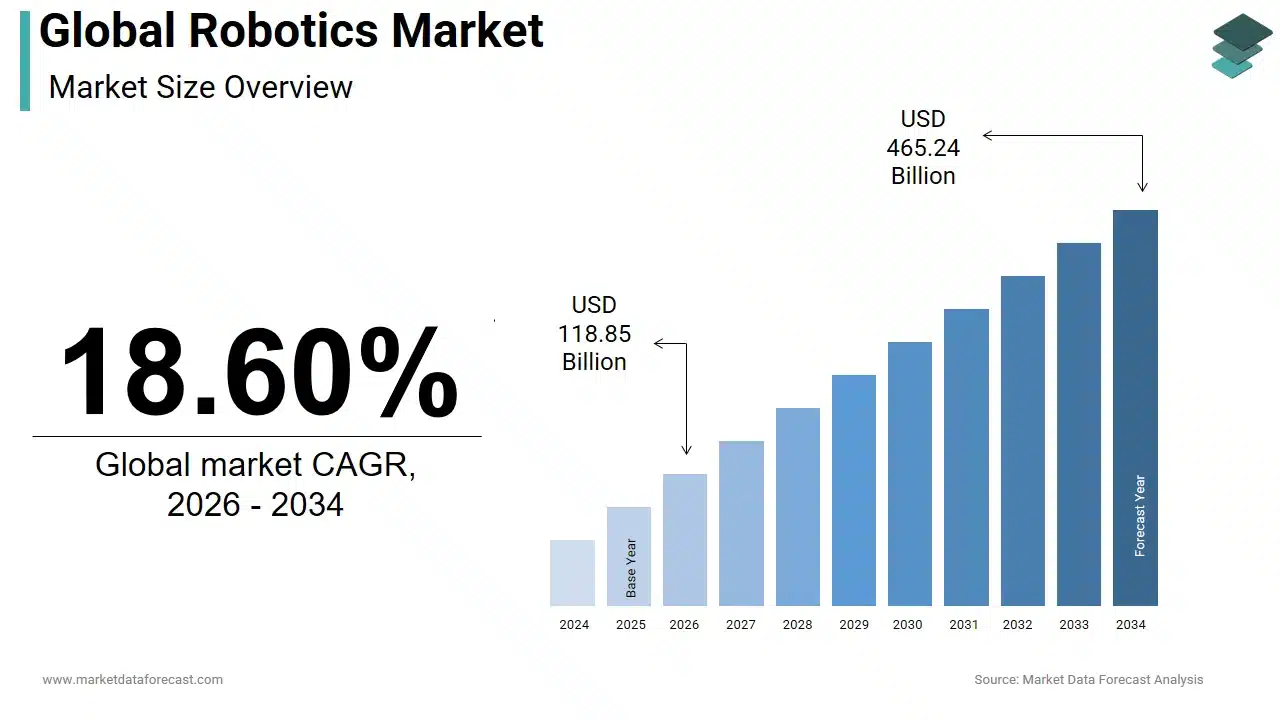
The growth of industrial robot deployments globally reflects these added capabilities. According to the International Federation of Robotics (IFR), collaborative robots (cobots) now account for 12% of annual market deployments, doubling their unit count between 2020 and 2024. While total operational stock has reached over 4.6 million active robots worldwide, IFR projects that new annual installations alone will surpass 700,000 units per year by 2028.[1] The image below [2] shows how this translates to market size, which roughly quadruples in the next 8 years, according to this data-driven projection.
Sensor Selection Across Robotic Architectures
Force sensing occurs at multiple mechanical junctions within a robotic system. Selecting the appropriate transducer depends on force directionality, space constraints, and high-frequency dynamic response requirements. The table below offers guidance.
| Robotic Sub-System | Sensing Technology & Application | ||
|---|---|---|---|
| Primary Transducer Type | Measurement Axis | Related Tacuna Systems Product | |
| Wrist & Tool Flange | Multi-Axis / Triaxial Load Cell | Vector force (\(F_x, F_y, F_z\)) and moments (\(M_x, M_y, M_z\)) |
Multi-Axis Load Cells |
| Motor Joints & Actuators | Rotary & Reaction Torque Transducers | Rotational moment (\(M_x\)) | Torque Transducers |
| Tendon & Cable Drives | Miniature Load Button / Tension Link | Axial tension / compression (\(F_z\)) | Miniature Load Buttons |
| Effector Fingertips | Tactile Skin / Optoelectronic Array | Distributed surface contact & micro-slip | Soft material contact testing via Micro Load Buttons |
Conclusion
Load cells and sensors are vital in the progress of robotics technology, along with AI, other programming advancements, and materials innovations. Together, these are enabling increasingly delicate and precise applications. For further exploration of flexible robotic architectures, see our companion guide: Continuum Robots and Tactile Sensors.
References and Further Reading
[1] International Federation of Robotics (IFR), World Robotics 2025 Report: Industrial Robots.
[2] Market Data Forecast, Global Robotics Market Size, Share, & Trends Report.
[3] DC Advisory, Gripping M&A – The Extending Arm of Robotics.
[4] Isaac Maw, Eye Spy: The Basics of Robotic Vision Systems, Engineering.com.
[5] Tanya M. Anandan, Force and Tactile Sensors Give Robots a Feel for the Job, Association for Advancing Automation (A3).
[6] Brian Dunn, Load Cells: Introduction and Applications.